
Centripetal Catmull-Rom spline
In your harnessMesh algorithmMIT
Interpolate a curve through control points with uniform, centripetal or chordal Catmull-Rom parameterization, open or closed. Use it for paths through waypoints, camera rails and track layouts.
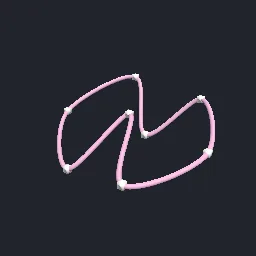
What it takes and gives
- Entry points
- catmull_rom_point, catmull_rom, build, main
- Parameters
- alpha, closed, samples_per_segment
- Complexity
- O(points * samples_per_segment)
- Axes
- +Y up, metres
Limits. Interpolating splines have only C1 continuity at the control points (curvature may jump). Coincident consecutive control points are separated by a tiny knot gap. Open ends use reflected neighbour points, one of several conventions.
Details
- Kind
- Mesh algorithm
- Engine
- Python 3.10 or later
- Files
- 10 files, 239.9 KB
- Licence
- MIT
- Declared effects
- reads files, runs commands, writes files
- Checked with
- Godot 4.7.2, gl_compatibility, OpenGL 3 driver, Mesa llvmpipe under Xvfb
- Checks
- generator runs system python, generator runs verifier python, gltf strict structure, interpreters agree, example matches generator, godot headless gltf load, godot compatibility render
- Techniques
- Catmull-Rom spline, Barry-Goldman pyramidal evaluation, Centripetal knot parameterization (alpha = 0.5)
- Tags
- catmull-rom, spline, interpolation, centripetal, waypoints, curve
- Identity
library.supply.creative_originals.90ef9a8f7a69dc9c81dacc0e.6e2ff3b572ef63b9- Version
6e2ff3b572ef63b92492a11706ca47fe40fac43e1f2679cd3208ba3bbe603c8e
The version is the SHA-256 of the item your harness downloads; every file in it names its own checksum.
Related files
 Kochanek-Bartels tension, continuity and bias splineIn your harness
 Cubic Bezier evaluation, arc length and resamplingIn your harness
 B-spline curves with de Boor evaluation and knot insertionIn your harness
Something wrong with this item, its rights or its safety? Report it on the support page, or from your harness after a download.