
Uniform point sets on the 3-sphere
In your harness4D geometry toolMIT
Sample unit quaternions three ways (normalized Gaussians, a Hopf fibration grid, a super-Fibonacci spiral), measure separation, covering radius and cap discrepancy against the exact cap volume of S3, and write the stereographic image as a glTF point cloud.
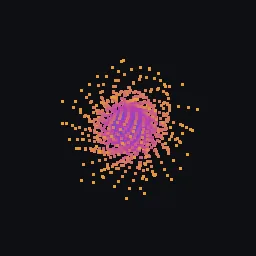
What it takes and gives
- Entry points
- gaussian, fibonacci_sphere, lift, hopf_map, hopf_grid, super_fibonacci, sample, cap_fraction and 7 more
- Outputs
- example.gltf
- Coordinates
- unit quaternions (x, y, z, w) = w + xi + yj + zk; stereographic image from (0, 0, 0, 1), Godot/glTF +Y up
Limits. Separation is an O(n^2) scan and covering radius and discrepancy are estimates from random probes and caps, so they suit sets of a few thousand points. The hopf_grid rounds the count to bases times fibre points. Points whose image lies beyond the clip radius (those near the projection pole) are left out of the glTF. POINTS render at one pixel in most viewers.
Details
- Kind
- 4D geometry tool
- Engine
- Python 3.10 or later
- Files
- 10 files, 179.3 KB
- Licence
- MIT
- Declared effects
- reads files, runs commands, writes files
- Checked with
- Godot 4.7.2, gl_compatibility (opengl3, Mesa llvmpipe under Xvfb)
- Checks
- cli rebuilds example, gltf structure example, cli example runs, cli example gltf structure, godot loads example, godot loads cli hopf grid, preview render
- Techniques
- uniform sampling by normalized Gaussian vectors, Hopf fibration as a Riemannian submersion, Fibonacci spiral on S2, super-Fibonacci spirals for S3, volume of a spherical cap on S3, stereographic projection
- Tags
- 4d, 3-sphere, sampling, unit quaternions, super-fibonacci, hopf fibration, point cloud, gltf
- Identity
library.supply.creative_originals.53e4f1fe65d1260e6d5df89d.da5350be82ea5309- Version
da5350be82ea5309cafb4344e3b6e683b2c216242334fa81c8c93d4be3b500f7
The version is the SHA-256 of the item your harness downloads; every file in it names its own checksum.
Related files
 Hopf fibration fibres as linked circlesIn your harness
 Clifford torus in the 3-sphereIn your harness
 4D rotations as pairs of unit quaternionsIn your harness
Something wrong with this item, its rights or its safety? Report it on the support page, or from your harness after a download.